Jiayi Jin
Hi, I'm Jiayi Jin. I am a Mechanical Engineering Ph.D. candidate at UW-Madison. I received my bachelor's degree in Mechanical Engineering from Tsinghua University in 2024. My current research interests lie in the design, simulation, and learning-based co-optimization of underwater bio-inspired robots. Besides, I am also a lover of landscape photographing.
Publications
Dynamics Modeling and Swimming Optimization of Robotic Fish with Various Local Body Stiffness
IEEE Robotics and Automation Letters, 2026
bib / code / video
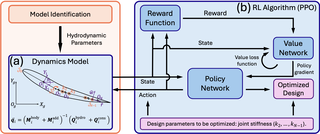
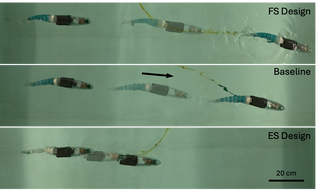
Body flexibility plays a significant role in fish propulsion and has been increasingly incorporated into robotic fish design. However, the functional significance of spatially varying body stiffness observed in real fish remains insufficiently under stood. This letter presents a reinforcement learning framework for optimizing the distributed passive stiffness of a motor-driven robotic fish. A multi-link dynamics model was developed to approximate continuously varying body stiffness, and its hydro dynamic parameters were identified and validated through swimming experiments. Based on the optimized stiffness distributions, we fabricated two robotic fish tails targeting fast swimming and energy-saving swimming, respectively. Experiments at the target operating condition show that the fast-swimming design increased swimming speed by 36.1% compared with the baseline, while the energy-saving design reduced the experimental cost of transport by 53.5%. Numerical fluid-structure simulations further reveal that the fast-swimming design strengthens wake vortices for increased thrust, whereas the energy-saving design promotes passive posterior deformation and an asymmetric wake associated with the lower cost of transport. These results demonstrate that distributed stiffness tuning provides an effective mechanism for improving robotic fish performance and offer design guidelines for bio-inspired flexible swimmers.
Design and Dynamic Modeling of a Flying Fish Robot with Experimental Validation
2026 IEEE International Conference on Robotics and Automation (ICRA), 2026
bib / video
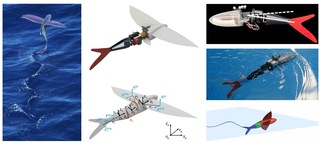
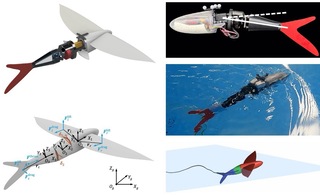
Flying fish have often served as an inspiration for engineering designs due to their remarkable ability for cross-domain locomotion between water and air. Previous observations and simulations suggest that taxiing behavior before takeoff is indispensable, yet the mechanics of this transition remain unclear. In this work, we present the design and dynamic modeling of a robotic flying fish to investigate swimming and taxiing locomotion, with a particular focus on tail pitching. We develop a bio-inspired prototype with an active tail-pitching structure and a high-power-density tail-beating propulsion system. We further formulate a cross-domain dynamic model that couples hydrodynamic and aerodynamic forces during taxiing. Simulations show that pitching the tail downward increases peak height and enables the robot to leave the water at a more aerodynamically favorable angle of attack. Experiments with the robotic prototype validate these trends and show that downward tail pitching increases upward force and body elevation with only minor loss of forward speed. These results provide insight into the role of tail pitching in flying fish taxiing and takeoff preparation.
Computational Design of Customized Vacuum-Driven Soft Grippers
IEEE Robotics and Automation Letters, 2024
bib / code / video
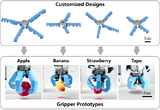
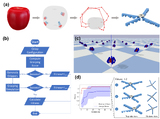
Soft grippers are increasingly favored due to their passive compliance, lack of need for precise force control, and high adaptability to various object shapes. Unlike previous soft grippers that are mostly universal, we propose a framework for the computational design and rapid fabrication of customized soft grippers using a specific class of vacuum-driven pneumatic actuators. The algorithm can automatically generate a 3D-printable model of the optimized gripper design, and then the gripper can be rapidly fabricated at a low cost. Grasping experiments demonstrate that this framework can customize grippers for various daily objects with different geometries. The results also show the extensional abilities of customizing a gripper for multiple or heavy objects. This framework enables the rapid design and fabrication of grippers optimized for specific tasks while maintaining versatility for handling various objects.
Data-driven inpainting for full-part temperature monitoring in additive manufacturing
Journal of Manufacturing Systems, 2024
bib
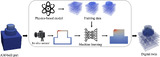
Understanding the temperature history over a part during additive manufacturing (AM) is important for optimizing the process and ensuring product quality, as temperature impacts melt pool geometry, defect formation, and microstructure evolution. While in-process temperature monitoring holds promise for evaluating the part quality, existing thermal sensors used in AM provide only partial measurements of the temperature distribution over the part. In this work, we introduce an innovative approach for reconstructing the complete temperature profile using partial data. We formulate this challenge as an inpainting problem, a canonical task in machine learning which entails recovering missing information across a spatial domain. We present a data-driven model based on graph convolutional neural networks. To train the inpainting model, we employ a finite element simulation to generate a diverse dataset of temperature histories for various part geometries. Cross-validation indicates that the inpainting model accurately reconstructs the spatial distribution of part temperature with strong generalizability across various geometries. Further application to experimental data using infrared camera measurements shows that the model accuracy could be improved by augmenting the training data with simulation data that shares process parameters and geometry with the experimental part. By presenting a solution to the temperature inpainting problem, our approach not only improves the assessment of part quality using partial measurements but also paves the way for the creation of a temperature digital twin of the part using thermal sensors.